
Multimodal interfaces for robot teleoperation
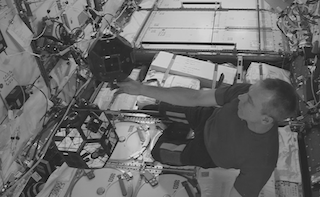
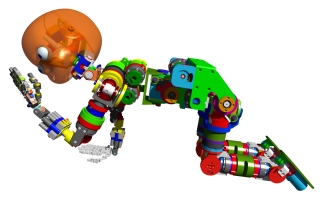
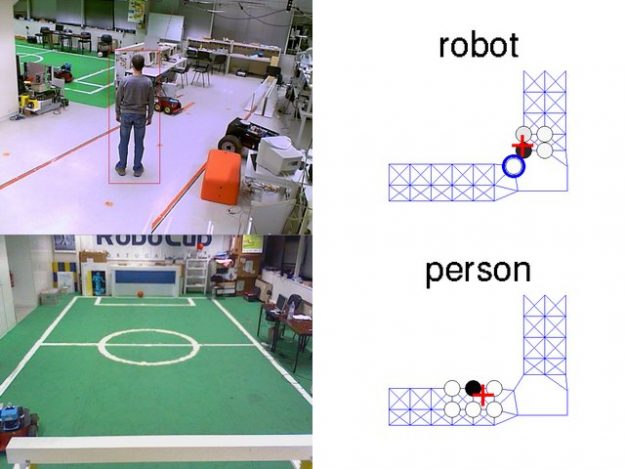
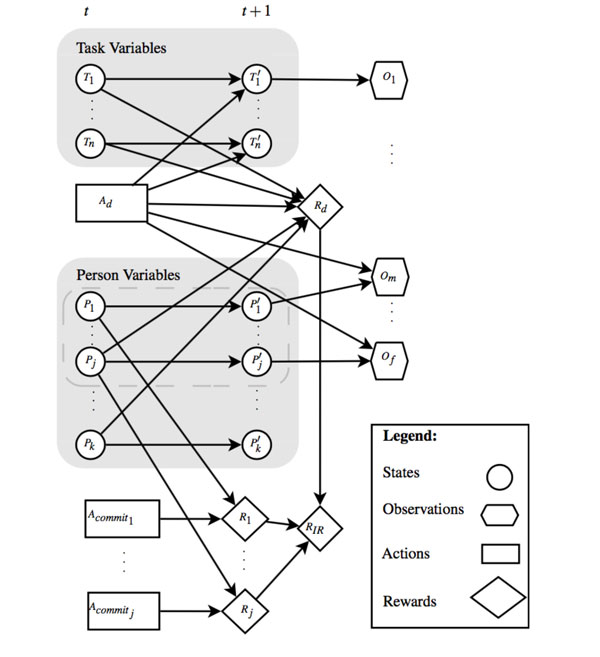
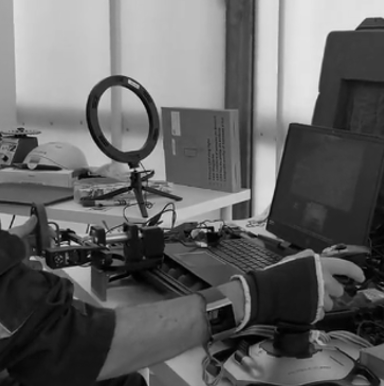
Multimodal interfaces for robot teleoperation: This research topic is focused on the design of novel multimodal robot teleoperation interfaces. While teleoperating a robot sharing the same physical area than the operator is typically straightforward, since the operator can follow the situation with his/her own eyes, when the teleoperation is remote, such as in the case…